Multi-Pole Magnetic Ring Magnetization is an important manufacturing process for permanent magnetic components used in motors, magnetic encoders, sensors, and other rotary systems. Unlike simple two-pole magnetization, multi-pole charging creates alternating north and south poles around the circumference of a magnetic ring.
The number of poles, magnetic field strength, pole width, transition angle, and magnetic uniformity all influence the performance of the finished component. For this reason, precise charging equipment and magnetic inspection are essential when producing high-quality multi-pole magnetic rings.
What Is Multi-Pole Magnetic Ring Magnetization?
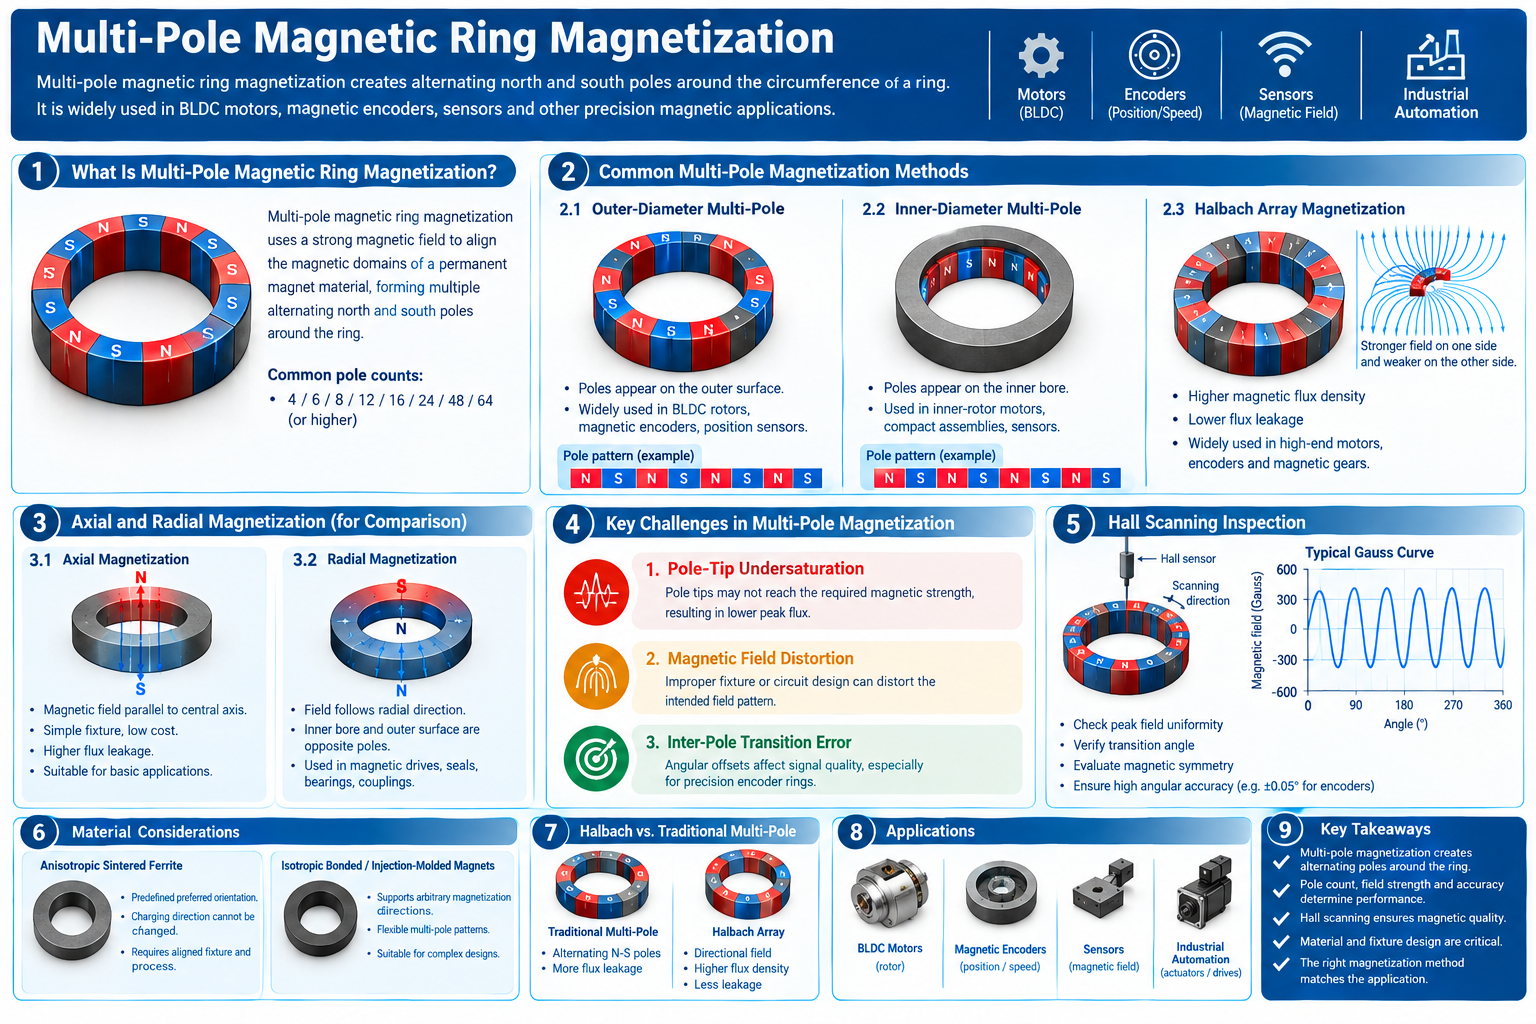
Multi-Pole Magnetic Ring Magnetization creates multiple alternating magnetic poles around the circumference of a permanent magnetic ring.
A typical pattern can be represented as:
N-S-N-S-N-S-N-S
The exact number of poles depends on the application. Common configurations include 4, 6, 8, 12, 16, 24, 48, and 64 poles, while specialized encoder applications may require even higher pole counts.
During charging, a specially designed fixture generates a strong magnetic field at specific locations around the ring. The magnetic field aligns the internal magnetic domains and establishes the required pole pattern.
After the charging field is removed, the magnetic material retains remanent magnetization.
Why Multi-Pole Magnetic Ring Magnetization Matters
The main purpose of Multi-Pole Magnetic Ring Magnetization is to create a controlled magnetic waveform around a rotating component.
When a magnetized ring rotates near a Hall sensor or another magnetic sensing element, each magnetic pole produces a corresponding change in the detected magnetic field.
The resulting electrical signal can be used for:
- Motor commutation
- Rotational speed detection
- Position feedback
- Magnetic encoder systems
- Motion control
- Rotary sensing
Therefore, the magnetic pattern is not simply a collection of individual poles. It is an important part of the overall motor or sensing system.
Outer-Diameter Multi-Pole Magnetic Rings
One common type of Multi-Pole Magnetic Ring Magnetization produces poles on the outer diameter of the ring.
The north and south poles alternate around the outside circumference.
This structure is frequently used in BLDC motor rotors and magnetic encoder rings.
Applications of Outer Multi-Pole Rings
Typical applications include:
- BLDC motor rotors
- Permanent magnet motor components
- Magnetic encoders
- Rotary position sensors
- Speed sensing systems
- Compact actuators
The external magnetic field interacts with sensors or stator structures positioned around the outside of the ring.
Inner-Diameter Multi-Pole Magnetization
Another configuration places alternating poles on the inner diameter.
In this structure, the magnetic field emerges primarily from the internal bore of the ring.
This type of Multi-Pole Magnetic Ring Magnetization is useful for applications where the magnetic interaction occurs inside the ring.
Typical Applications
Inner multi-pole rings can be used in:
- Inner-rotor motors
- Integrated motor assemblies
- Internal magnetic sensors
- Compact rotary mechanisms
- Specialized encoder structures
The selection between inner and outer pole arrangements depends on the mechanical structure and location of the magnetic sensor or air gap.
Magnetic Pole Count and Ring Performance
Pole count is one of the most important design parameters for a multi-pole magnetic ring.
Increasing the number of poles creates more magnetic transitions around the circumference. This can provide more signal cycles during one mechanical revolution.
However, higher pole counts also make the manufacturing process more demanding.
For example, a ring with 8 poles has much wider individual pole sections than a ring with 48 or 64 poles.
As pole width becomes smaller, the charging fixture needs greater positional accuracy.
Common Pole Counts
Depending on the application, designers may use:
- 4 poles
- 6 poles
- 8 poles
- 12 poles
- 16 poles
- 24 poles
- 48 poles
- 64 poles
- Higher specialized pole counts
The appropriate configuration should be determined according to the motor design, sensor characteristics, rotational speed, and required feedback resolution.
Challenges in Multi-Pole Magnetic Ring Magnetization
High-precision Multi-Pole Magnetic Ring Magnetization requires careful control of the magnetic circuit and charging fixture.
Several technical problems can influence the final magnetic waveform.
Pole Tip Undersaturation
When the charging field is not sufficiently concentrated at a narrow pole area, the pole may not reach the required magnetic strength.
This can result in lower magnetic peaks and inconsistent signals between poles.
Magnetic Field Distortion
The magnetic circuit must generate the intended field pattern at each charging position.
An unsuitable fixture may cause field distortion, resulting in uneven pole strength or irregular magnetic transitions.
Angular Position Error
Each magnetic pole needs to be positioned accurately around the circumference.
Even when the magnetic strength is acceptable, an angular offset between poles can affect encoder signal accuracy.
This is particularly important for precision magnetic encoder rings.
Hall Scanning Inspection for Multi-Pole Rings
Hall scanning is commonly used to evaluate Multi-Pole Magnetic Ring Magnetization after charging.
A Hall sensor scans the magnetic field around the circumference and records the magnetic strength at different angular positions.
The resulting Gauss curve provides valuable information about the quality of the magnetic pattern.
Peak Field Uniformity
The peak value of each pole can be compared with neighboring poles.
A consistent ring should produce relatively uniform magnetic peaks according to the design requirements.
Significant differences may indicate problems with the material, fixture, positioning, or charging conditions.
Transition Angle
The transition between adjacent north and south poles can be measured from the magnetic waveform.
Accurate transition angles are particularly important for encoder applications because the magnetic signal is related to mechanical position.
Magnetic Symmetry
The complete circumferential waveform can also be checked for symmetry.
Uneven magnetic distribution may indicate:
- Fixture misalignment
- Material variation
- Incorrect charging conditions
- Magnetic circuit imbalance
- Dimensional errors
Hall scanning therefore provides an important quality-control step for precision magnetic rings.
Materials Used for Multi-Pole Magnetic Rings
The material has a significant influence on Multi-Pole Magnetic Ring Magnetization.
Different permanent magnetic materials have different magnetic strength, orientation characteristics, temperature behavior, and charging requirements.
Sintered Ferrite
Sintered ferrite is widely used where cost, temperature resistance, and suitable magnetic performance are important.
For anisotropic ferrite, the preferred magnetic orientation is established during material forming.
The charging direction therefore needs to match the predefined orientation.
Bonded NdFeB
Bonded NdFeB provides relatively high magnetic performance while offering flexibility in manufacturing complex shapes.
It can be used for customized magnetic rings with different pole configurations.
Injection-Molded Magnetic Materials
Injection molding allows magnetic materials to be formed into complex geometries and integrated into components with precise dimensional requirements.
Isotropic injection-molded magnetic materials also provide considerable flexibility in designing magnetization patterns.
This makes them suitable for specialized motor rotors, encoder rings, and sensing components.
Multi-Pole Magnetic Ring Magnetization for BLDC Motors
BLDC motors are an important application for multi-pole magnetic rings.
The rotor ring contains alternating north and south poles around its circumference. As the rotor turns, the magnetic field interacts with the stator windings.
The number and position of the magnetic poles need to match the motor’s electromagnetic design.
Consistent charging helps maintain a uniform magnetic pattern and predictable motor behavior.
Poor pole uniformity or excessive angular error can contribute to differences in the magnetic signal and affect system performance.
Multi-Pole Magnetic Ring Magnetization for Encoders
Magnetic encoders rely on accurately distributed magnetic poles to generate position-related signals.
During rotation, the alternating magnetic pattern passes the sensing element and produces a periodic output.
Higher pole counts can create more magnetic transitions per revolution, but they also require greater manufacturing precision.
Important parameters include:
- Pole count
- Peak Gauss value
- Pole spacing
- Transition angle
- Magnetic symmetry
- Angular tolerance
- Air-gap distance
For precision encoder applications, the charging process and magnetic inspection should therefore be developed together.
Multi-Pole Magnetic Ring Magnetization and Air Gap
The air gap between the magnetic ring and sensor or stator is another important factor.
Magnetic field strength decreases as the distance from the magnetic source increases. Therefore, changes in the air gap can affect the detected signal.
A properly designed ring should provide sufficient magnetic field strength at the actual operating distance.
The final magnetic field should therefore be evaluated under conditions that are representative of the finished assembly.
Charging Fixture Design
The charging fixture is one of the most important tools in Multi-Pole Magnetic Ring Magnetization.
The fixture needs to generate the required magnetic field at precise angular positions.
For low-pole-count rings, the fixture design may be relatively straightforward.
For high-pole-count rings, the pole spacing becomes much smaller, increasing the requirements for:
- Fixture machining accuracy
- Magnetic circuit design
- Coil positioning
- Ring alignment
- Charging field strength
- Thermal management
- Mechanical stability
A small positioning error can become significant when the individual pole width is narrow.
Quality Control of Multi-Pole Magnetic Rings
A complete quality-control process should evaluate both dimensional and magnetic characteristics.
Typical inspection parameters include:
Dimensional Inspection
Important dimensions may include:
- Inner diameter
- Outer diameter
- Thickness
- Concentricity
- Pole reference features
Magnetic Inspection
Magnetic testing can evaluate:
- Peak magnetic field
- Pole-to-pole consistency
- Transition position
- Magnetic waveform
- Circumferential symmetry
- Residual magnetization
Combining dimensional inspection with magnetic testing helps identify problems that may not be visible through physical measurements alone.
Halbach Rings and Multi-Pole Magnetization
Halbach configurations represent a more advanced form of multi-directional magnetization.
Instead of simply alternating north and south poles around the circumference, different segments are magnetized at controlled angular orientations.
The resulting magnetic field is strengthened on one side and reduced on the opposite side.
This approach can provide:
- Higher useful magnetic flux
- Reduced leakage
- Directional magnetic fields
- Improved magnetic utilization
Halbach structures can be used in high-performance servos, precision magnetic systems, magnetic gears, and specialized motor designs.
Selecting Multi-Pole Magnetic Ring Magnetization Parameters
The correct charging parameters should be selected according to the final application.
Important factors include:
- Magnetic material
- Pole count
- Ring diameter
- Pole width
- Magnetic field strength
- Charging direction
- Sensor position
- Operating air gap
- Required angular accuracy
- Operating temperature
A motor rotor may prioritize magnetic strength and pole consistency, while an encoder may place greater emphasis on angular accuracy and waveform uniformity.
Therefore, the charging process should be customized according to the actual system requirements.
Conclusion
Multi-Pole Magnetic Ring Magnetization is a key process for producing magnetic rings used in BLDC motors, magnetic encoders, sensors, and other rotary systems.
The process creates alternating magnetic poles around the inner or outer circumference of a ring. Pole count, magnetic strength, transition angle, field uniformity, and air-gap conditions all influence the final performance.
As the pole count increases, the individual pole width becomes smaller and the requirements for charging fixture accuracy and magnetic circuit design become more demanding.
Hall scanning provides an effective method for evaluating the resulting Gauss curve, including peak uniformity, transition angle, and magnetic symmetry.
By combining suitable magnetic materials, accurate charging fixtures, controlled magnetization parameters, and reliable inspection methods, manufacturers can produce multi-pole magnetic rings suitable for demanding motor, encoder, sensing, and automation applications.